Control of Complex Systems

1 999,00 kr
+ 91,99 kr Leverans

Control of Complex Systems
Säljs av:

1 999,00 kr

I lager
+ 91,99 kr Leverans

14-dagars returpolicy

Köparskydd

Betalningsmetoder:

  • Märke: Unbranded

Produktinformation

Produktinformation

Control of Complex Systems

1. Introduction. - 1. 1 Complex Systems and Control. - 1. 2 Complex Engineering Systems. - 1. 3 The Role of Feedback. - 1. 4 Dynamics and Control. - 1. 5 The Nature of Failures. - 1. 6 Research Challenges. - 1. 7 About the Book. - 2. Modeling Complex Physical Systems. - 2. 1 Introduction. - 2. 2 The Modelica Project. - 2. 3 Composition Diagrams. - 2. 4 Modelica Details. - 2. 5 Non-causal Modeling. - 2. 6 Advanced Modeling Features. - 2. 7 Standard Libraries. - 2. 8 Future Development. - 2. 9 Conclusions. - 3. Passivity-based Control of Non-linear Systems. - 3. 1 Introduction. - 3. 2 Passivity and Stability Analysis of Feedback Interconnections. - 3. 3 Feedback Passivity and Stabilization. - 3. 4 Euler-Lagrange Systems. - 3. 5 Disturbance Attenuation and R oo Control. - 4. An Introduction to Forwarding. - 4. 1 Introduction. - 4. 2 C1 Dissipative Systems. - 4. 3 C1 Dis sipative Systems via Reduction or Extension. - 4. 4 Exact Change of Coordinates. - 4. 5 Approximate Change of Coordinates. - 5. Iterative Identification and Control Design. - 5. 1 Introduction. - 5. 2 Youla Parametrization. - 5. 3 A Generic Two-degree of Freedom Controller. - 5. 4 Optimization of the Generic Scheme. - 5. 5 A New Closed-loop System Parametrization. - 5. 6 Asymptotic Variances for K-B-Parametrization. - 5. 7 Iterative Controller Refinement. - 5. 8 Robustness and Sensitivity. - 5. 9 Product Inequalities. - 6. Learning Control of Complex Systems. - 6. 1 Introduction. - 6. 2 Model Structures for Learning. - 6. 3 Control Structures for Learning. - 6. 4 Learning Paradigms. - 6. 5 A General Framework for On-line Learning. - 6. 6 Validation. - 6. 7 Conclusions. - 7. Software for Complex Controllers. - 7. 1 Introduction. - 7. 2 An Evolving Paradigm. - 7. 3 Emerging Software Concepts. - 7. 4 On to Standardization. - 7. 5 Sample Complex Software Controllers. - 7. 6 The Future of Software for Control. -8. Fault-tolerant Control Systems. - 8. 1 Introduction. - 8. 2 Basic Definitions. - 8. 3 Analysis of Fault Propagation. - 8. 4 Analysis of Structure. - 8. 5 Recoverability. - 8. 6 Autonomous Fault-tolerant Control. - 8. 7 An Example: Ship Propulsio. - 8. 8 Summary. - 9. Fault Detection and Isolation. - 9. 1 The Principle of Model-based Fault Diagnosis. - 9. 2 Signal-based FDI Approach. - 9. 3 Quantitative Model-based FDI Approach. - 9. 4 Qualitative Model-based FDI Approach. - 9. 5 Summary. - 10. Residual Generation for FDI in Non-linear Systems. - 10. 1 Introduction. - 10. 2 Algebraic Approach. - 10. 3 Geometric Approach. - 10. 4 Conclusion. - 11. Predictive Methods for FTC. - 11. 1 Introduction. - 11. 2 Predictive Control. - 11. 3 Embedding Fault Tolerance in Predictive Control. - 11. 4 Model Adaptation and Management. - 11. 5 Modifying Control Objectives. - 11. 6 Current Industrial Practice. - 11. 7 Conclusions. - 12. Three-tank Control Reconfiguration. - 12. 1 The Benchmark Problem. - 12. 2 Reconfigurability Analysis. - 12. 3 Reconfiguration Based on a Qualitative Model. - 12. 4 A Hybrid Approach to Reconfigurable Control. - 12. 5 A Multi-model-based Reconfigurable Control. - 12. 6 A Neural Observer-based Approach. - 12. 7 Conclusions. - 13. Ship Propulsion Control and Reconfiguration. - 13. 1 Introduction. - 13. 2 Ship Propulsion System. - 13. 3 Structural Analysis. - 13. 4 Fault Detection: A Fuzzy Observer Approach. - 13. 5 Fault Detection: Non-linear Approach - 1. - 13. 6 Fault Detection: Non-linear Approach - 2. - 13. 7 Reconfiguration Using Software Redundancy. - 13. 8 Reconfiguration Using Predictive Control. - 13. 9 Summary and Conclusions. - 14. Learning Control of Thermal Systems. - 14. 1 Introduction. - 14. 2 On Thermal System Learning Control. - 14. 3 Controlling Kiln Heat Processing. - 14. 4 Controlling Reheat Furnace Processes. - 14. 5 Hierarchical Control for Quality Ceramic Tiles. - 14. 6 Learning Control ofFBC Combustion. - 14. 7 Conclusions and Future Research. - 15. Vibration Control of High-rise Buildings. - 15. 1 Introduction. - 15. 2 Energy and Information. - 15. 3 Analytical Mechanics and HRB Modelling. - 15. 4 Disturbance Decoupling. - 15. 5 Passivity Based Control. - 15. 6 Engineering Constraints and Feedback. - 15. 7 Feedback Control and Testing. - 15. 8 Conclusions and Future Research. - 16. Control of Helicopters. - 16. 1 Introduction. - 16. 2 Project History. - 16. 3 The COSY Program. - 16. 4 Hardware System. - 16. 5 Software. - 16. 6 Design of the Autopilot. - 16. 7 Future Development. - 16. 8 Conclusions. - 17. Satellite Attitude Control. - 17. 1 Introduction to the Attitude Control Problem. - 17. 2 Fault-tolerant Control of the 0RSTED Satellite. - 17. 3 Stabilization of the Angular Velocity of a Rigid Body. - 17. 4 Optimal Slew Maneuvers via Geometric Control Theory. - 17. 5 Attitude Control using Magnetorquers as Sole Actuators. - 17. 6 Predictive Attitude Control of Small Satellites. - 17. 7 Attitude Determination without Sensor Redundancy. - 17. 8 Summary. - Appendix A. List of Contributors. - Appendix B. List of Abbreviations. - References. Language: English
  • Märke: Unbranded
  • Kategori: Utbildning
  • Artist: Karl J. Aström
  • Format: Paperback
  • Publiceringsdatum: 2012/09/27
  • Sidantal: 482
  • Förläggare / Bolag: Springer
  • Språk: English
  • Fruugo-ID: 337872348-741531648
  • ISBN: 9781447110743
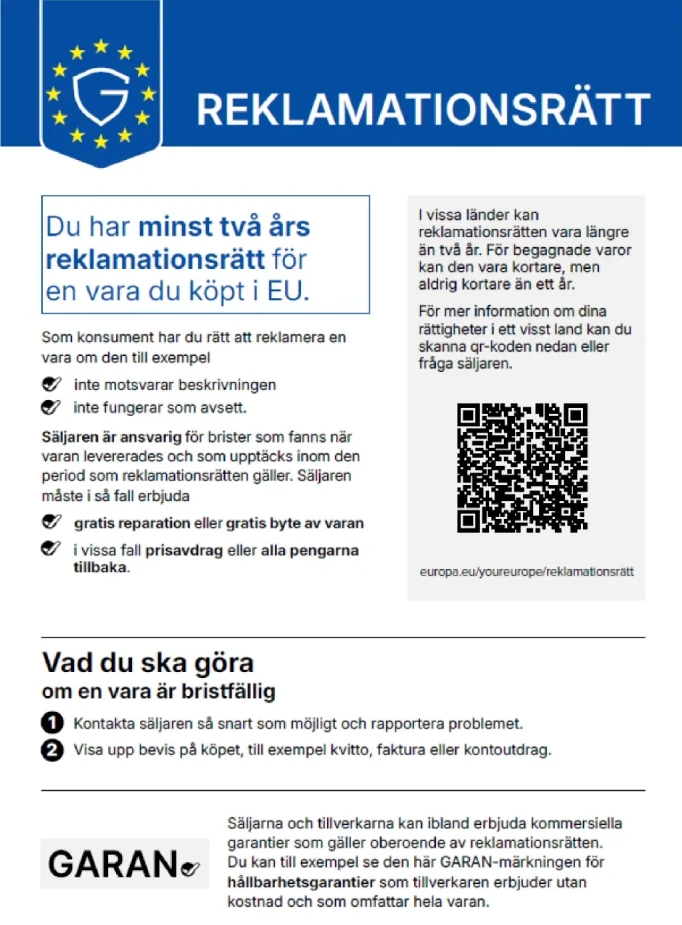
Löfte

Säljarens garanti

2 års lagstadgad garanti ingår

Dina EU-konsumenträttigheter inkluderar en kostnadsfri minst 2-årig lagstadgad garanti

Ladda ner lagstadgad garanti för överensstämmelse
Leverans

Leverans

Skickas inom 5 dagar

  • STANDARD: 91,99 kr - Leverans mellan kl tis 13 oktober 2026–fre 16 oktober 2026

Leverans från Storbritannien.

Returer

Returer och avbokningar

Returer

Vi gör vårt bästa för att säkerställa att produkterna du beställer levereras kompletta och enligt dina specifikationer. Om du däremot skulle ta emot en ofullständig beställning, eller andra artiklar än de du beställt, eller om det finns någon annan anledning till att du inte är nöjd med din beställning, kan du returnera beställningen, eller valfria produkter som ingår i beställningen, och få fullständig ersättning för artiklarna.

Visa fullständig returpolicy

Avbokningar

Du har rätt att ångra ditt köp inom 14 dagar från att du mottagit din beställning utan att ange någon anledning. För att enkelt utöva din rätt kan du använda länken "Avbryt min beställning" i sidfoten på varje sida eller i ditt Fruugo-konto under "Beställningar". När du har utnyttjat din ångerrätt skickar vi dig en e-postbekräftelse. Om din beställning redan har skickats av återförsäljaren kommer vi att förse dig med nödvändiga returinstruktioner för att säkerställa att din återbetalning behandlas snabbt.

Visa fullständig avbokningspolicy