1 682,87 kr
+ 96,49 kr Leverans

Parallel Robots

Säljs av:

1 682,87 kr

I lager
+ 96,49 kr Leverans

14-dagars returpolicy

Köparskydd

Betalningsmetoder:

  • Märke: Unbranded

Produktinformation

Produktinformation

Parallel Robots

Parallel structures are more effective than serial ones for industrial automation applications that require high precision and stiffness or a high load capacity relative to robot weight. Although many industrial applications have adopted parallel structures for their design few textbooks introduce the analysis of such robots in terms of dynamics and control. Filling this gap Parallel Robots: Mechanics and Control presents a systematic approach to analyze the kinematics dynamics and control of parallel robots. It brings together analysis and design tools for engineers and researchers who want to design and implement parallel structures in industry. Covers Kinematics Dynamics and Control in One Volume The book begins with the representation of motion of robots and the kinematic analysis of parallel manipulators. Moving beyond static positioning it then examines a systematic approach to performing Jacobian analysis. A special feature of the book is its detailed coverage of the dynamics and control of parallel manipulators. The text examines dynamic analysis using the Newton-Euler method the principle of virtual work and the Lagrange formulations. Finally the book elaborates on the control of parallel robots considering both motion and force control. It introduces various model-free and model-based controllers and develops robust and adaptive control schemes. It also addresses redundancy resolution schemes in detail. Analysis and Design Tools to Help You Create Parallel Robots In each chapter the author revisits the same case studies to show how the techniques may be applied. The case studies include a planar cable-driven parallel robot part of a promising new generation of parallel structures that will allow for larger workspaces. The MATLABÂ code used for analysis and simulation is available online. Combining the analysis of kinematics and dynamics with methods of designing controllers this text offers a holistic introduction for anyone interested in designing and implementing parallel robots. . Language: English
  • Märke: Unbranded
  • Kategori: Utbildning
  • Artist: Hamid D. Taghirad
  • Format: Paperback
  • Publiceringsdatum: 2017/03/29
  • Förläggare / Bolag: CRC Press
  • Språk: English
  • Fruugo-ID: 337602402-741240325
  • ISBN: 9781138077386
Löfte

Säljarens garanti

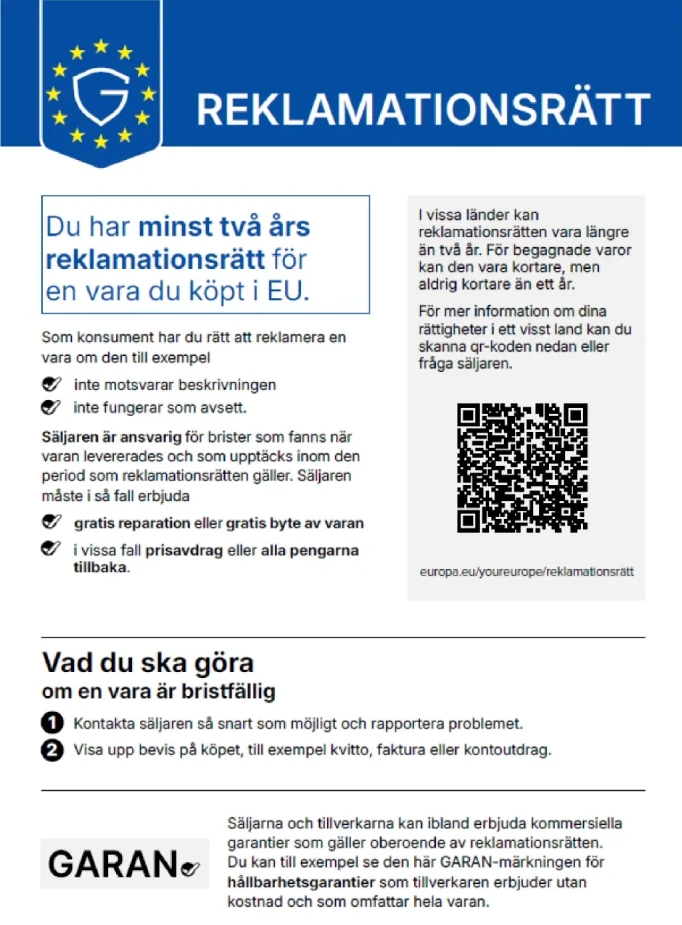
2 års lagstadgad garanti ingår

Dina EU-konsumenträttigheter inkluderar en kostnadsfri minst 2-årig lagstadgad garanti

Ladda ner lagstadgad garanti för överensstämmelse
Leverans

Leverans

Skickas inom 5 dagar

  • STANDARD: 130,36 kr - Leverans mellan kl tis 13 oktober 2026–fre 16 oktober 2026

Leverans från Storbritannien.

Returer

Returer och avbokningar

Returer

Vi gör vårt bästa för att säkerställa att produkterna du beställer levereras kompletta och enligt dina specifikationer. Om du däremot skulle ta emot en ofullständig beställning, eller andra artiklar än de du beställt, eller om det finns någon annan anledning till att du inte är nöjd med din beställning, kan du returnera beställningen, eller valfria produkter som ingår i beställningen, och få fullständig ersättning för artiklarna.

Visa fullständig returpolicy

Avbokningar

Du har rätt att ångra ditt köp inom 14 dagar från att du mottagit din beställning utan att ange någon anledning. För att enkelt utöva din rätt kan du använda länken "Avbryt min beställning" i sidfoten på varje sida eller i ditt Fruugo-konto under "Beställningar". När du har utnyttjat din ångerrätt skickar vi dig en e-postbekräftelse. Om din beställning redan har skickats av återförsäljaren kommer vi att förse dig med nödvändiga returinstruktioner för att säkerställa att din återbetalning behandlas snabbt.

Visa fullständig avbokningspolicy