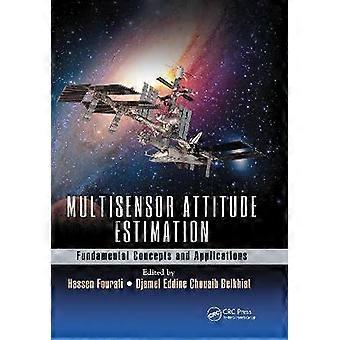
Multisensor Attitude Estimation

2 299,00 kr
+ 97,99 kr Leverans

Multisensor Attitude Estimation
Säljs av:

2 299,00 kr

I lager
+ 97,99 kr Leverans

14-dagars returpolicy

Köparskydd

Betalningsmetoder:

  • Märke: Unbranded

Produktinformation

Produktinformation

Multisensor Attitude Estimation

There has been an increasing interest in multi-disciplinary research on multisensor attitude estimation technology driven by its versatility and diverse areas of application such as sensor networks robotics navigation video biomedicine etc. Attitude estimation consists of the determination of rigid bodiesâ orientation in 3D space. This research area is a multilevel multifaceted process handling the automatic association correlation estimation and combination of data and information from several sources. Data fusion for attitude estimation is motivated by several issues and problems such as data imperfection data multi-modality data dimensionality processing framework etc. While many of these problems have been identified and heavily investigated no single data fusion algorithm is capable of addressing all the aforementioned challenges. The variety of methods in the literature focus on a subset of these issues to solve which would be determined based on the application in hand. Historically the problem of attitude estimation has been introduced by Grace Wahba in 1965 within the estimate of satellite attitude and aerospace applications. This book intends to provide the reader with both a generic and comprehensive view of contemporary data fusion methodologies for attitude estimation as well as the most recent researches and novel advances on multisensor attitude estimation task. It explores the design of algorithms and architectures benefits and challenging aspects as well as a broad array of disciplines including: navigation robotics biomedicine motion analysis etc. A number of issues that make data fusion for attitude estimation a challenging task and which will be discussed through the different chapters of the book are related to: 1) The nature of sensors and information sources (accelerometer gyroscope magnetometer GPS inclinometer etc. ); 2) The computational ability at the sensors; 3) The theoretical developments and convergence proofs; 4) The system architecture computational resources fusion level. . Language: English
  • Märke: Unbranded
  • Kategori: Utbildning
  • Format: Paperback
  • Publiceringsdatum: 2020/09/30
  • Förläggare / Bolag: CRC Press
  • Språk: English
  • Fruugo-ID: 337363073-740990706
  • ISBN: 9780367655815
Löfte

Säljarens garanti

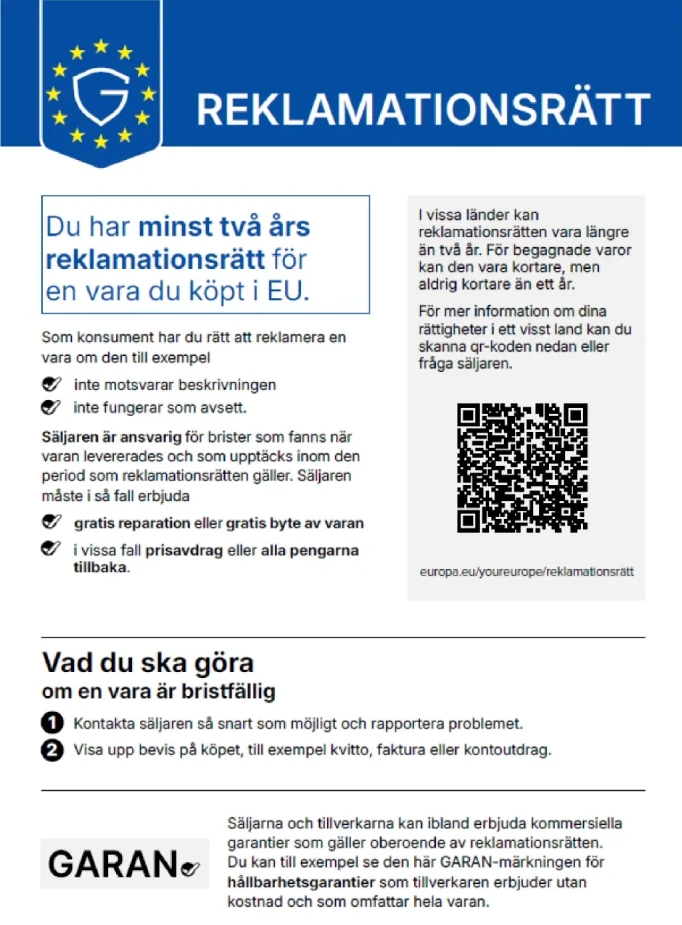
2 års lagstadgad garanti ingår

Dina EU-konsumenträttigheter inkluderar en kostnadsfri minst 2-årig lagstadgad garanti

Ladda ner lagstadgad garanti för överensstämmelse
Leverans

Leverans

Skickas inom 5 dagar

  • STANDARD: 97,99 kr - Leverans mellan kl tis 10 november 2026–fre 13 november 2026

Leverans från Storbritannien.

Returer

Returer och avbokningar

Returer

Vi gör vårt bästa för att säkerställa att produkterna du beställer levereras kompletta och enligt dina specifikationer. Om du däremot skulle ta emot en ofullständig beställning, eller andra artiklar än de du beställt, eller om det finns någon annan anledning till att du inte är nöjd med din beställning, kan du returnera beställningen, eller valfria produkter som ingår i beställningen, och få fullständig ersättning för artiklarna.

Visa fullständig returpolicy

Avbokningar

Du har rätt att ångra ditt köp inom 14 dagar från att du mottagit din beställning utan att ange någon anledning. För att enkelt utöva din rätt kan du använda länken "Avbryt min beställning" i sidfoten på varje sida eller i ditt Fruugo-konto under "Beställningar". När du har utnyttjat din ångerrätt skickar vi dig en e-postbekräftelse. Om din beställning redan har skickats av återförsäljaren kommer vi att förse dig med nödvändiga returinstruktioner för att säkerställa att din återbetalning behandlas snabbt.

Visa fullständig avbokningspolicy